I am a Ph.D. student at Purdue University, working in the MARS Lab with Prof. Yu She since Fall 2026. My current project is on dual-arm dexterous manipulation and tool manipulation, built on vision-language-action (VLA) models. Previously, I worked on multimodal perception for dexterous robotic hands at KIST, and built visuotactile reinforcement learning testbeds for deformable object manipulation during my M.Sc. at KAIST.
News
- Aug 2026 Started my Ph.D. at Purdue University, joining the MARS Lab advised by Prof. Yu She.
- Jun 2026 Our paper, KineFuse: Kinematic-Aware Haptic Fusion for In-Hand Occluded-Object Pose Tracking has been accepted to IROS 2026!
Publications
-
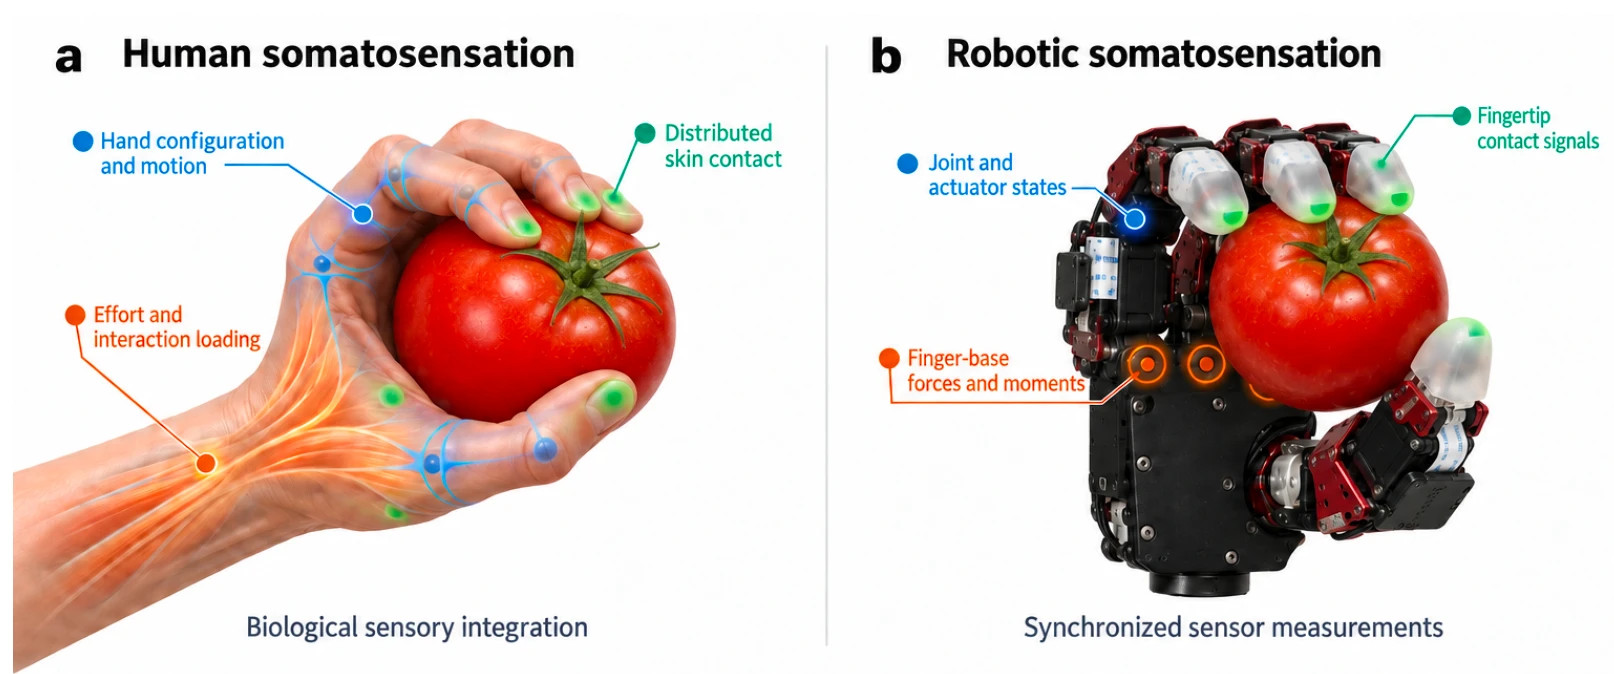 Multimodal somatosensory feedback enables physical-object inference and adaptive in-hand manipulationIn preparation (journal) 2026A robotic hand that synchronizes joint-state proprioception, finger-level interaction-wrench sensing, and fingertip tactile sensing into a single somatosensory state, used to infer physical properties and contact conditions, adapt grasp forces, and condition an in-hand manipulation policy.
- HaptiGate: Grasp-Stability Predictor Using Proprioceptive, Kinesthetic, and Tactile Sensing on a Multi-Fingered Robotic HandUnder review (conference) 2026Modality ablations on over 5,220 real-world grasps show that the haptic signal that matters depends on the task, and a prediction-gated recovery strategy raises real-robot grasp success from 64.6% to 77.1%.
- IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) 2026Travel Grant: WHPC @ Purdue · IEEE IES-SYPAA kinematic-aware, finger-level haptic encoder that complements a pretrained visual pose tracker when the fingers occlude the object, improving sequential tracking and downstream reorientation.
-
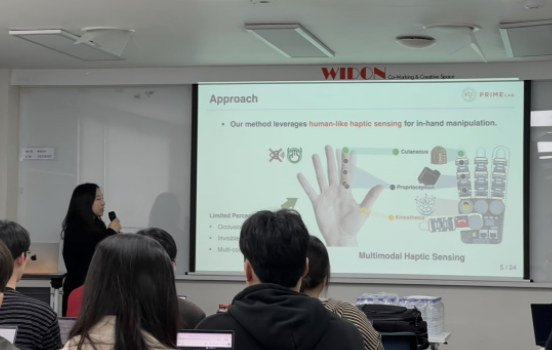
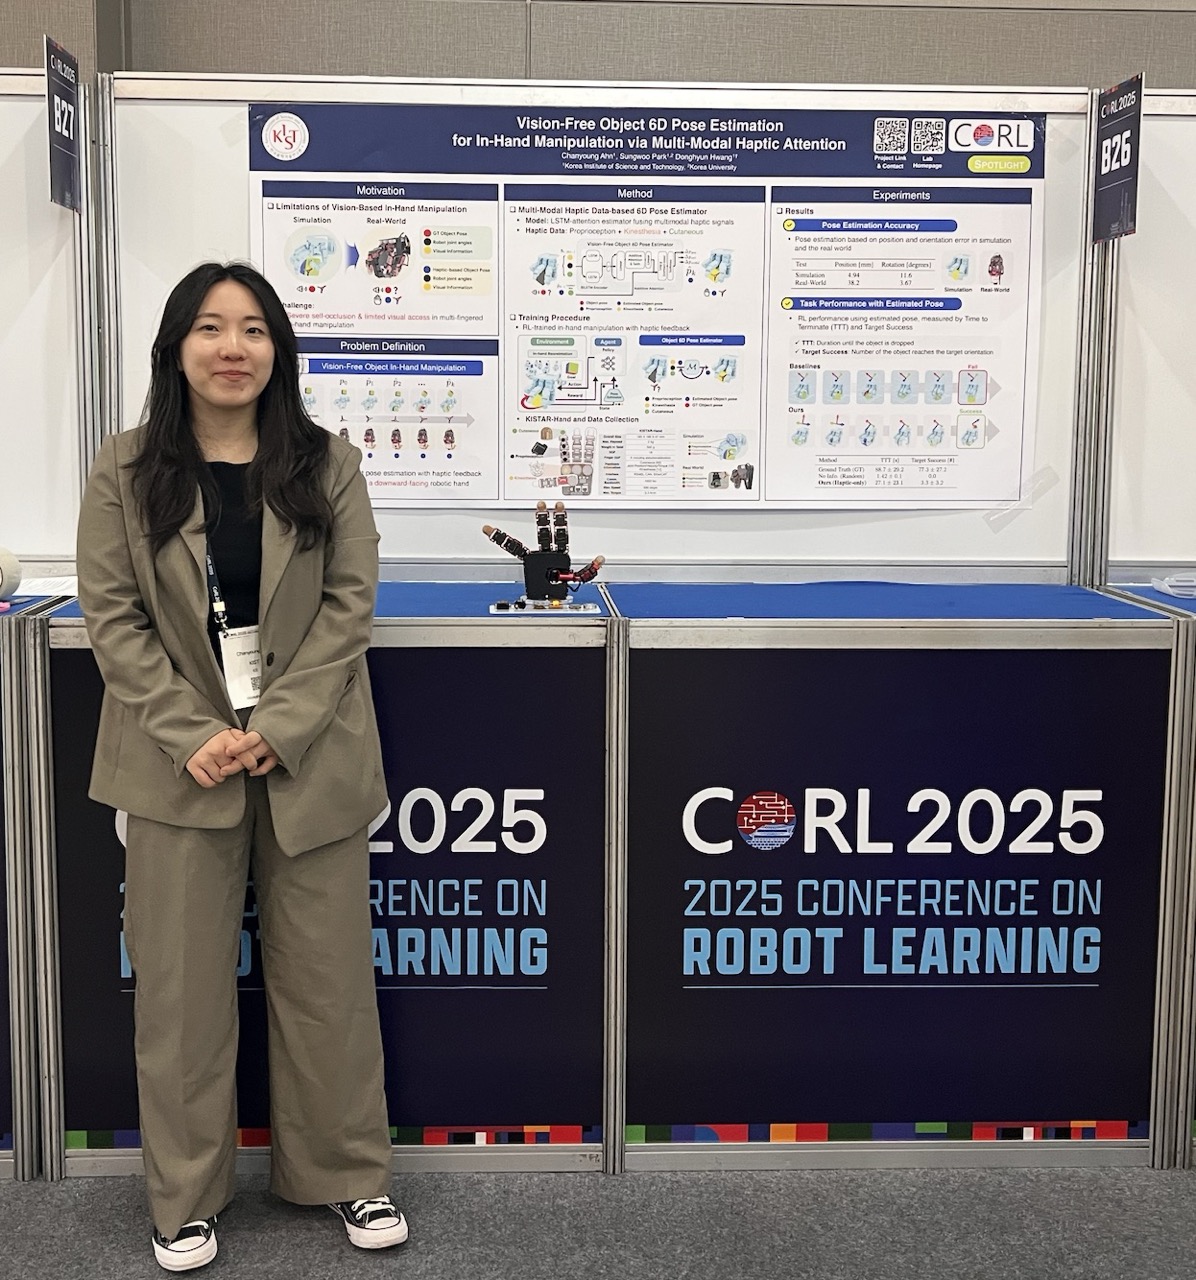
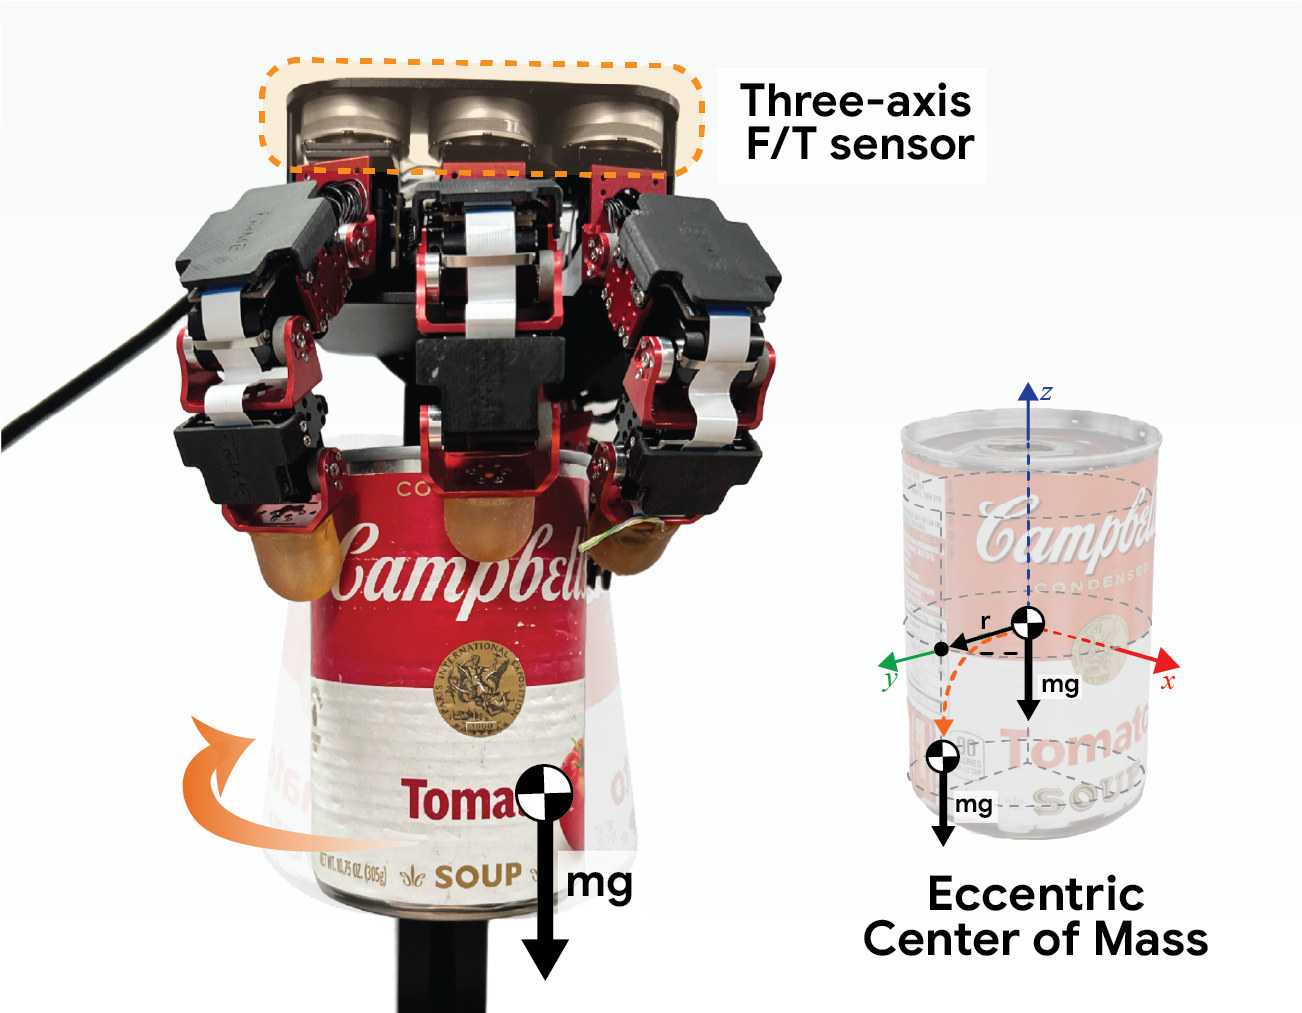
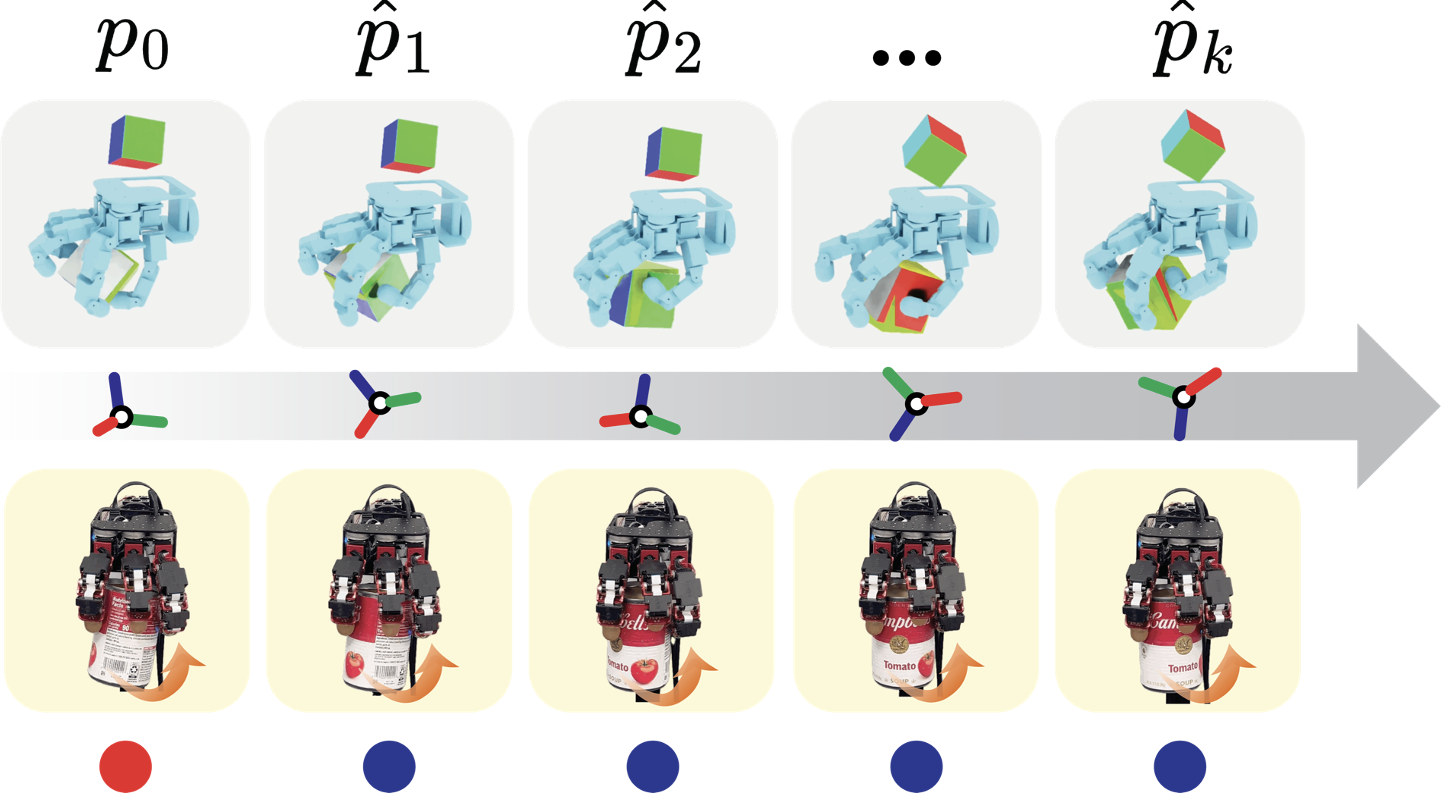 SpotlightCoRL Workshop, Dexterous Manipulation 2025A haptic attention estimator that infers object pose from kinesthetic, contact, and proprioceptive signals alone, with average errors of 4.94 mm and 11.6 degrees over 10 seconds of in-hand reorientation.
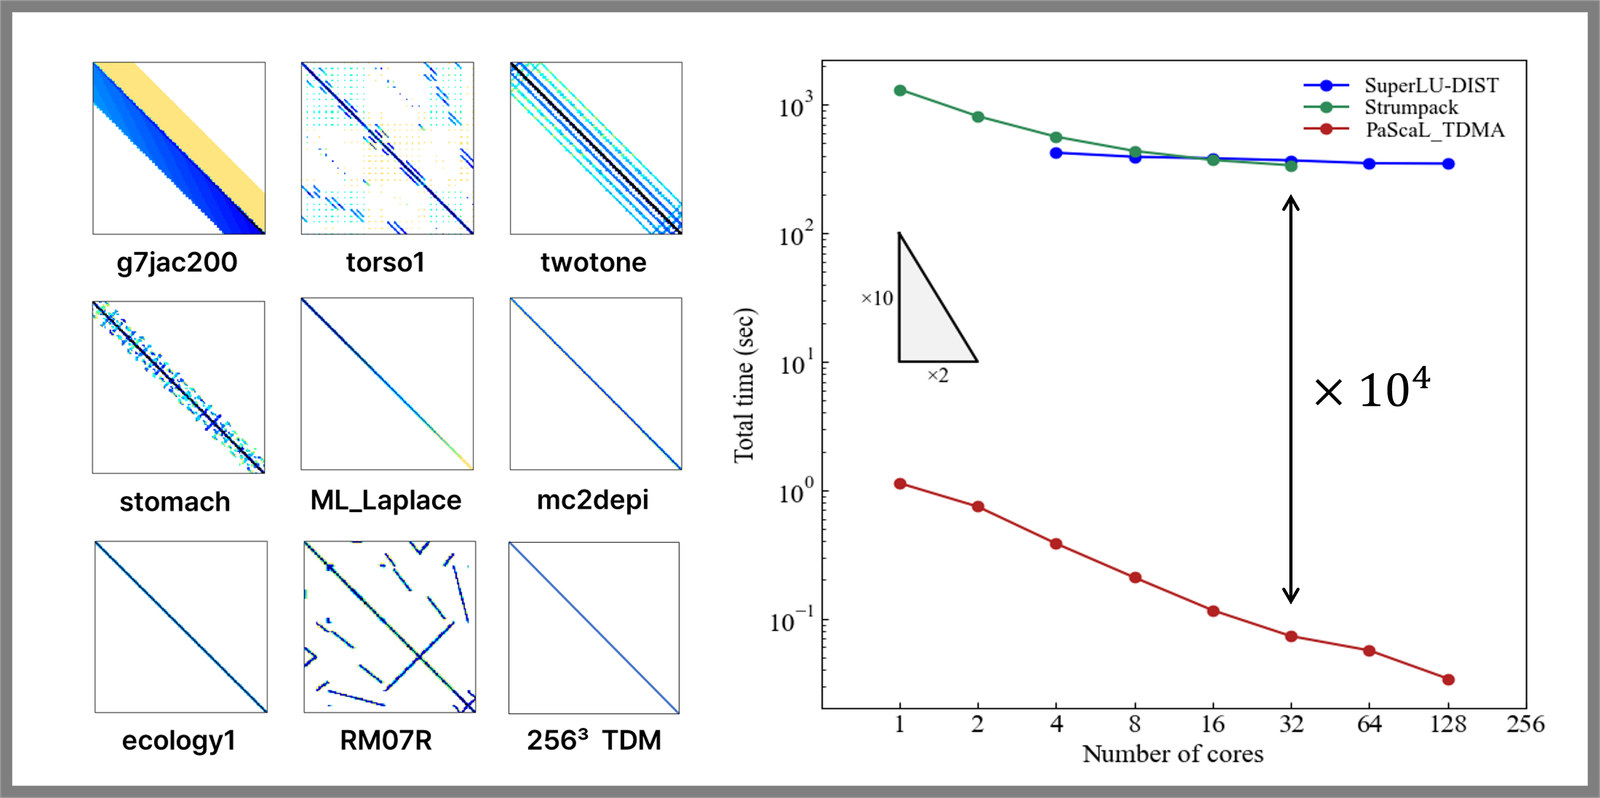
Projects
- Dual-Arm Dexterous Tool Manipulation with Sim-to-Real LearningMARS Lab, Purdue University 2026
-
General Engineering
-
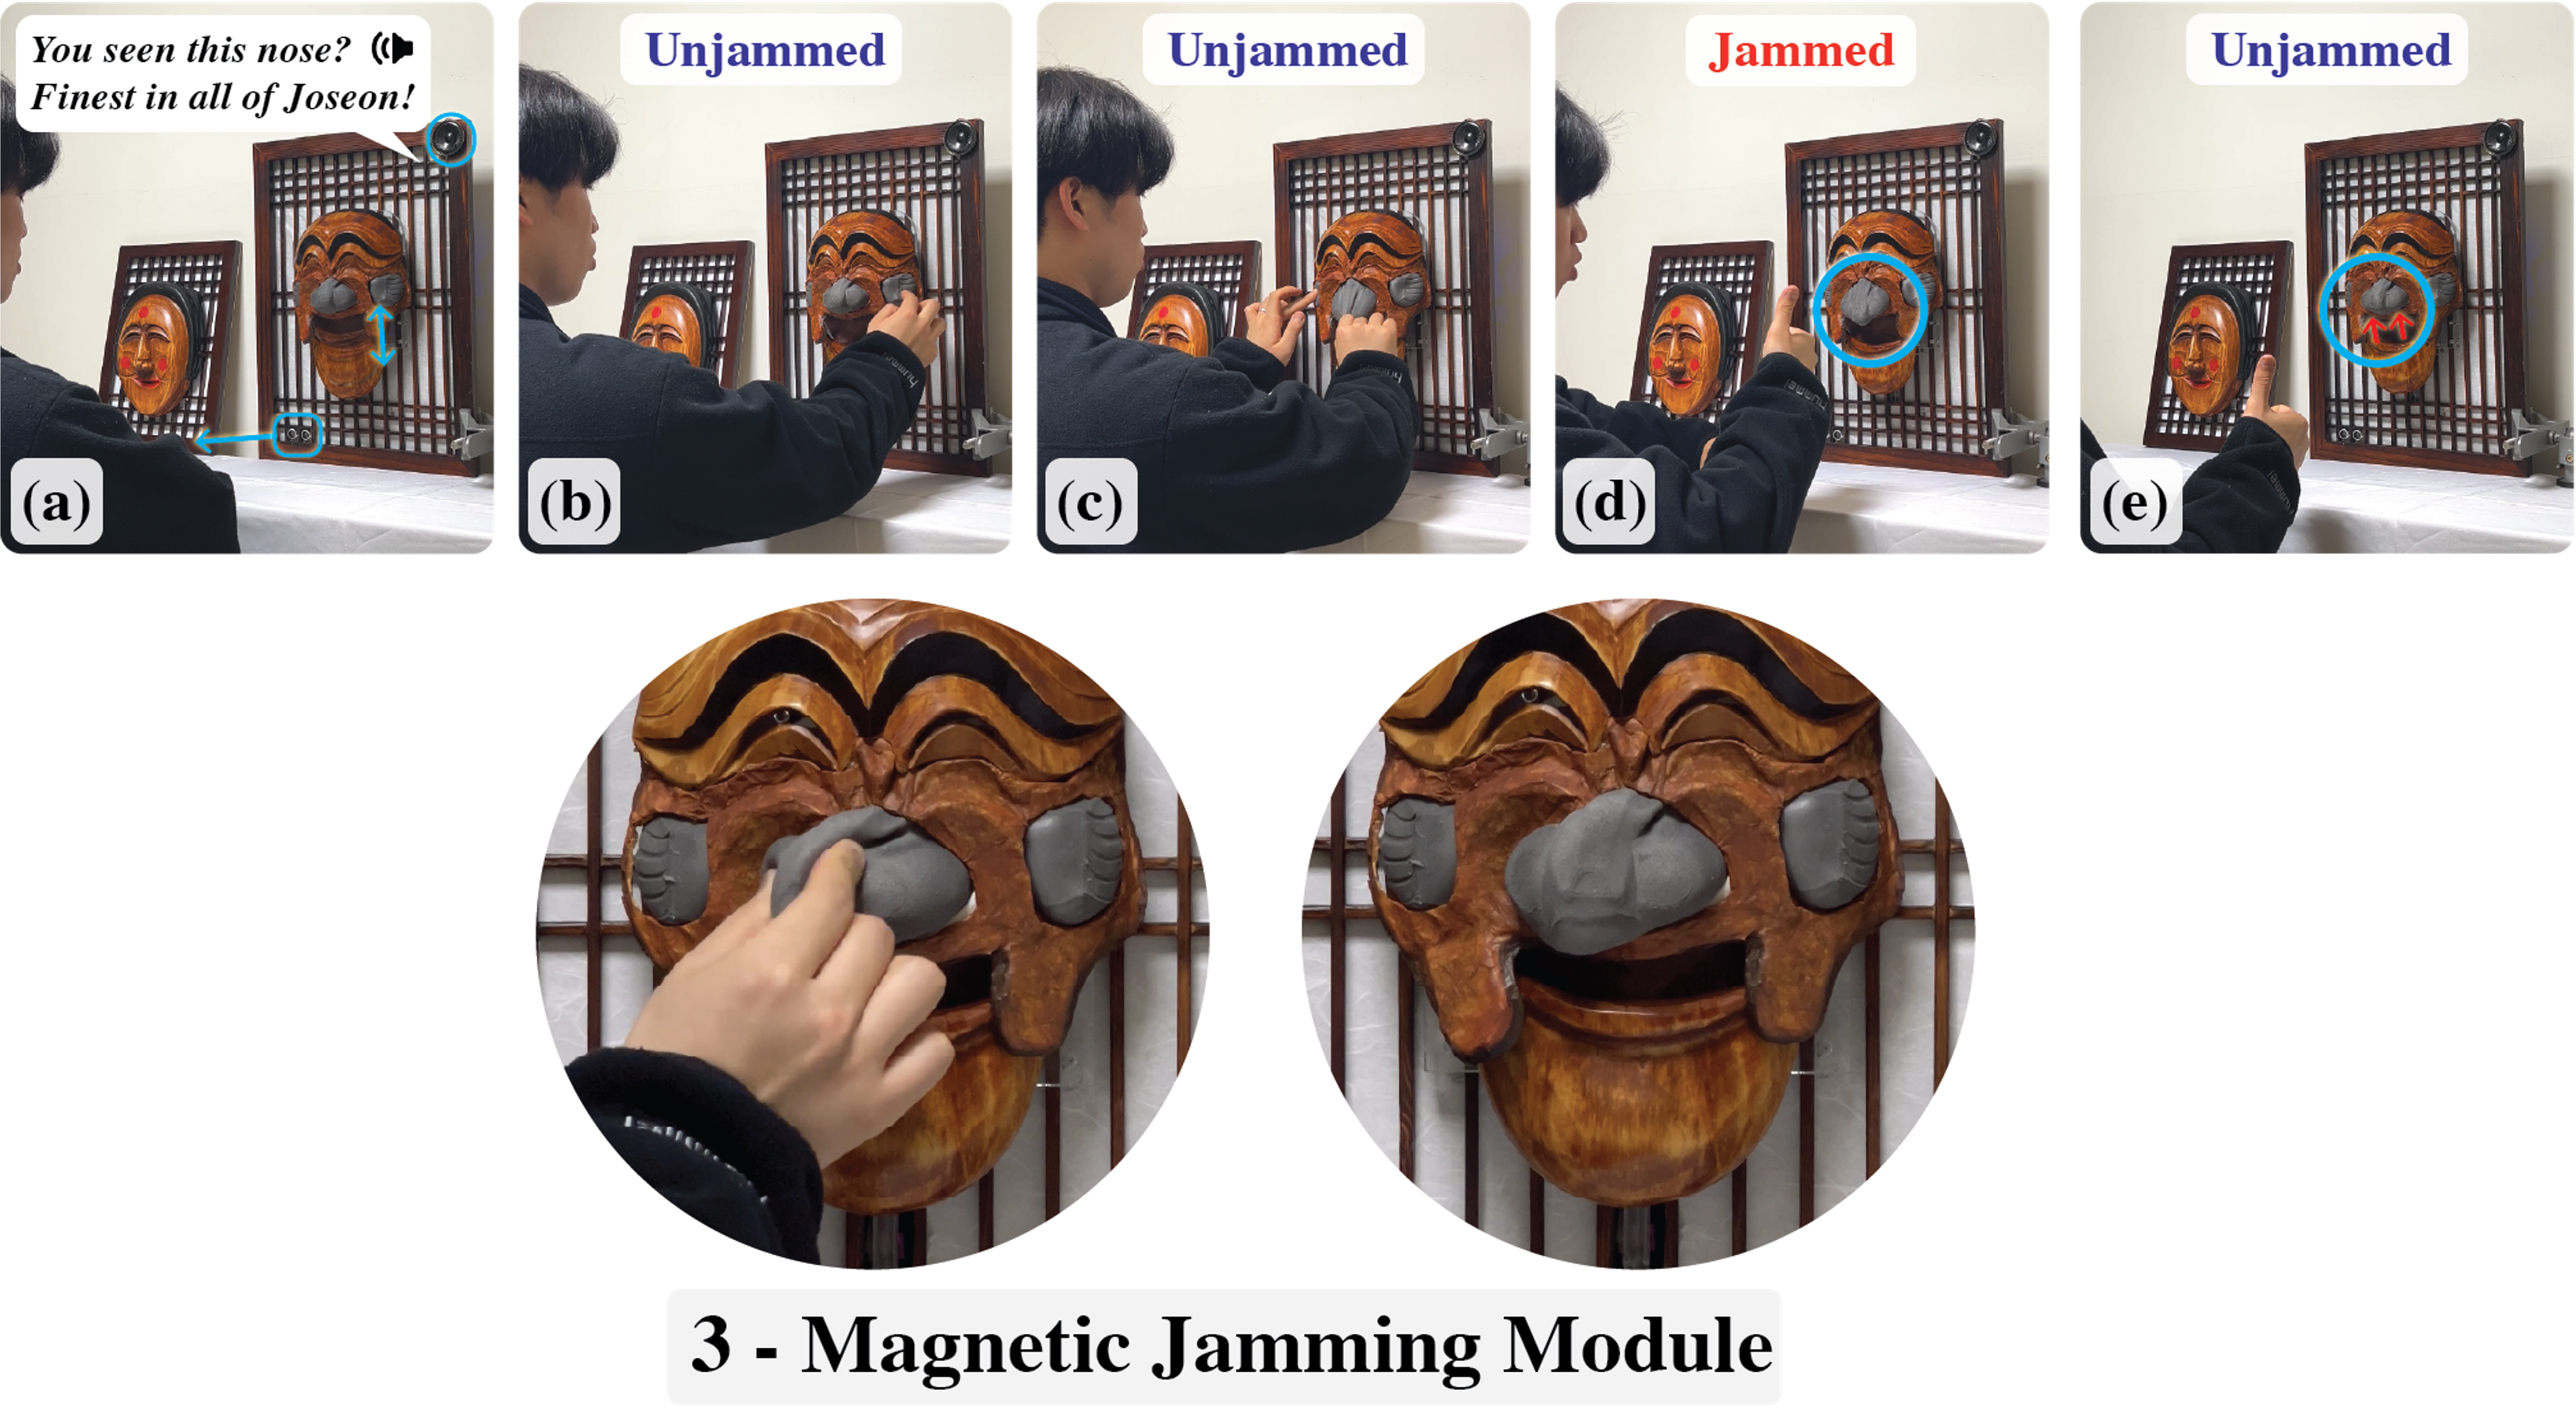 ICRA 2025 Arts in Robotics 2025
-
Skills
Simulation Isaac Sim (Lab), MuJoCo, Genesis, PyBullet
RL & ML PyTorch, Stable-Baselines3, RSL-RL
Hardware Denso, Franka, UR5e, KISTAR Hand, F/T sensors, tactile sensors
Programming Python, C++, ROS2
Teaching
Fall 2026 Teaching Assistant, IE 474 Industrial Control Systems, Purdue University
Academic Service
Peer Review T-RO · AIM · IROS · ICRA · ICRA Workshop · CoRL Workshop
Community KRoC Workshop (2025-2026, Korean Robotics Learning Research) · Graspium (KIST paper reading group)